Robotics
Robotics Projects
Mechanisms, end-effectors, and autonomous platforms — machines built to physically handle things that are never quite the same twice.
FEATURED PROJECT
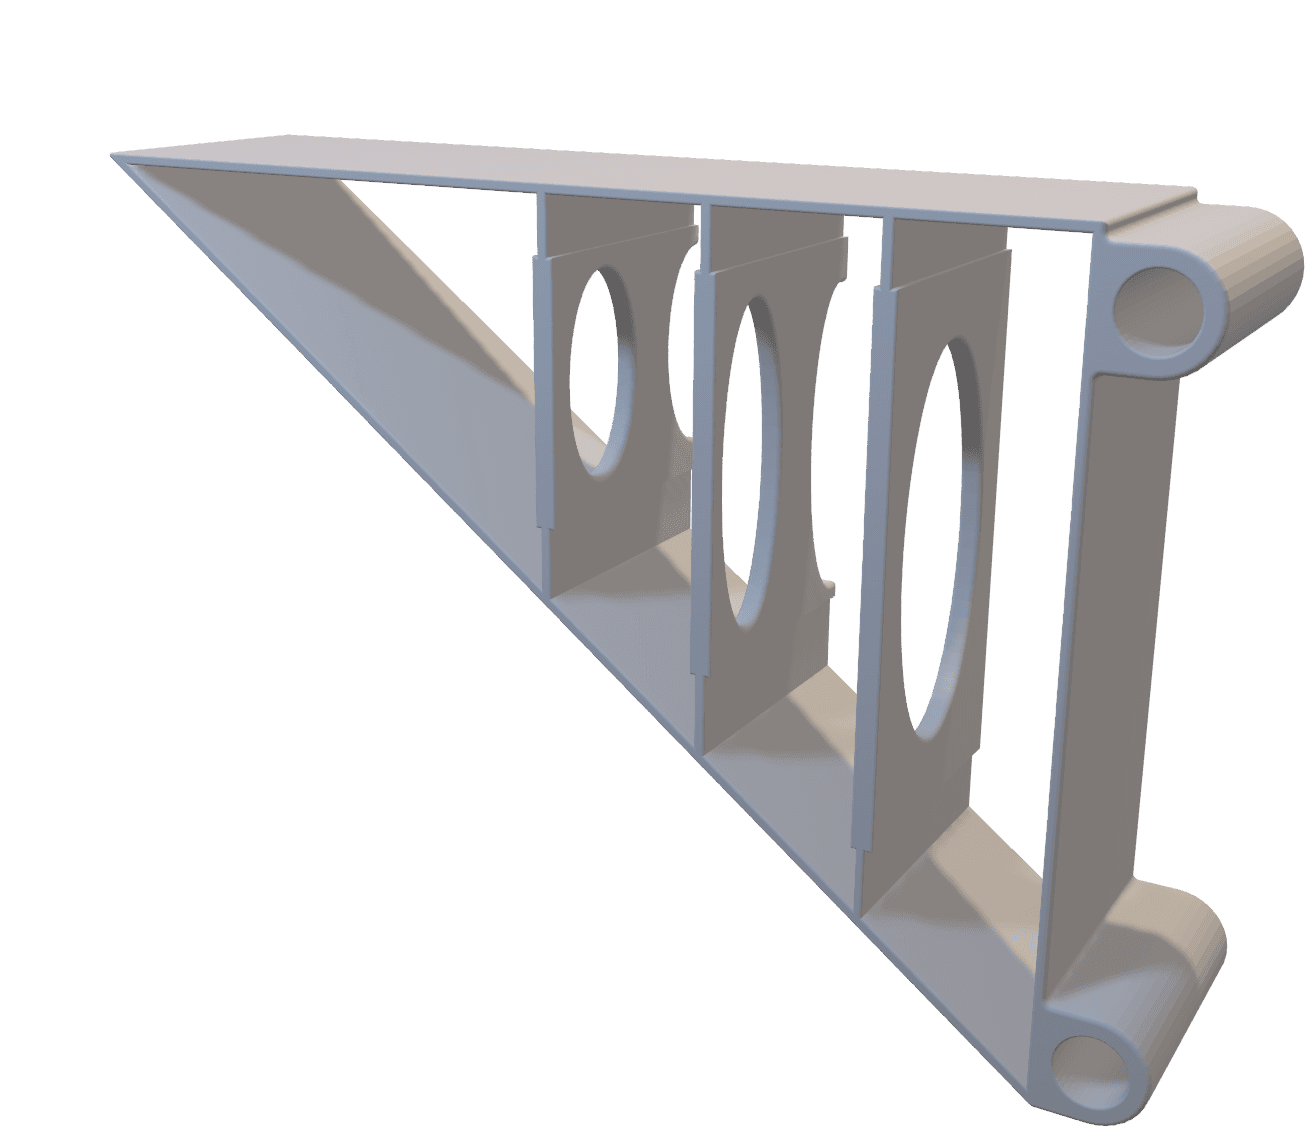
Soft Gripper Weight & Rigidity Optimization
A compliant end-effector for fruit and vegetable harvesting. I swept the constraint space in iterative FEA-based topology optimization, then reworked the optimizer's output into printable geometry — taking the finger from 130 g to 71 g without losing the compliant grip that keeps produce undamaged.
My Role
Topology optimization, FEA, and design for 3D printing.
Technologies
SolidWorks • Topology Optimization • FEA • FDM 3D Printing
Result
45% lighter at comparable simulated stress — printed and verified by hand.
UNIVERSITY PROJECT
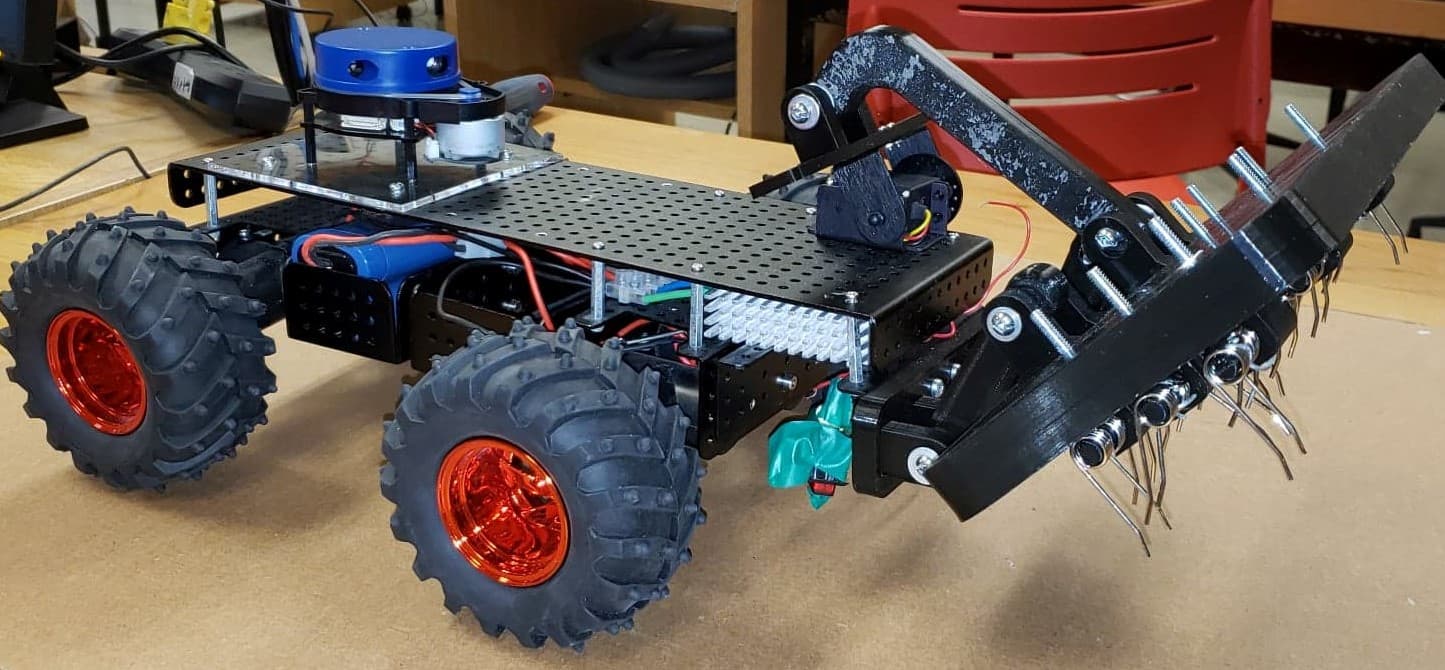
Autonomous Weed Management Robot
A mobile robot that pulls weeds mechanically instead of spraying them. I designed and fabricated the implement — a spring tine on a servo-driven parallel lift, 15 custom 3D-printed parts — and modified the chassis to carry it, trading two drive motors for the space and power the mechanism needed.
My Role
Mechanism design, CAD, 3D-printed fabrication, and integration onto the platform.
Technologies
SolidWorks • 3D Printing • ROS • Arduino • YDLIDAR X4 • Hector SLAM
Focus
Linkage design and soil-contact implement on an autonomous platform.
R&D PROJECT
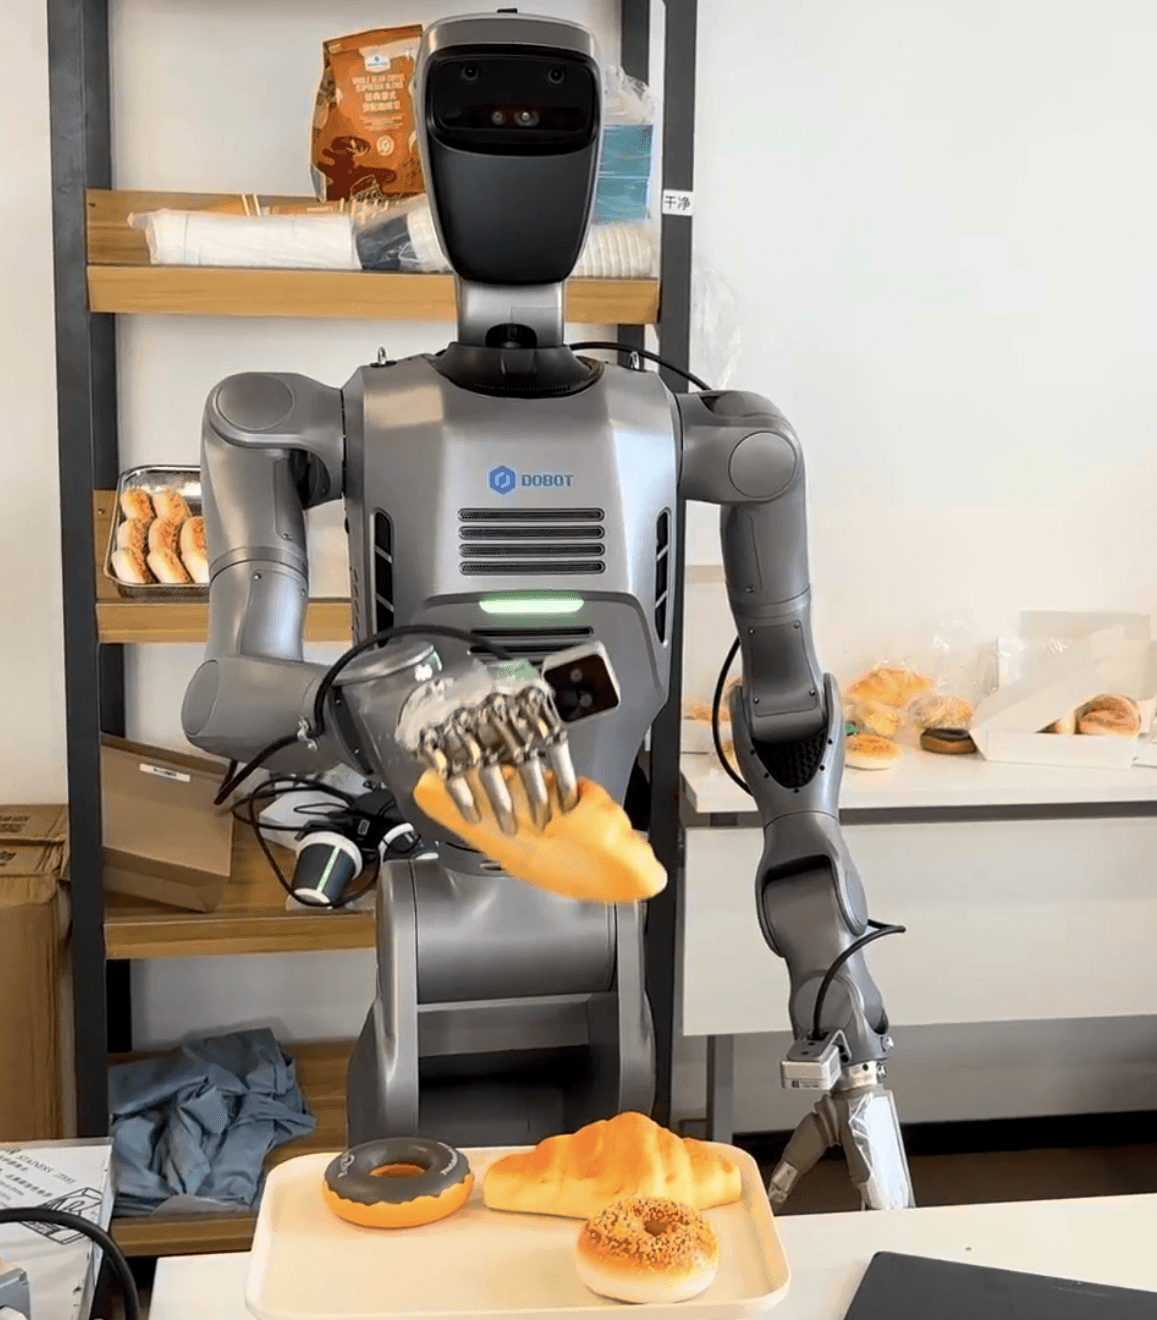
Autonomous Robot Café
An autonomous café system pairing a humanoid robot with a mobile platform to take orders and retrieve pastries — the same handling problem in a service setting, where the item being picked is soft and the tolerance for crushing it is zero.
My Role
AMR navigation, map configuration, waypoint planning, and movement optimization.
Technologies
DOBOT AtomW • ROS 2 • AMR • Teleoperation
Focus
Autonomous navigation and robotic pastry retrieval.