Mechanical Design • Robotics • Mechatronics
William Chen
Mechanical & Robotics Design Engineer
I design mechanisms for machines that physically handle things no two of which are alike — soft grippers, agricultural implements, food-processing systems. I started on the production floor building this kind of hardware, and I commission it on customer sites today. That's where I learned which designs survive and which ones only work in CAD.
About
I learned what breaks before I learned how to draw it.
My dream of becoming a mechatronics engineer started in 8th grade. I saw the SFU Mechatronics logo and a live demonstration at the Surrey Central campus, and I was hooked. That spark sent me to study Physics at KPU, and eventually led me right back to that same SFU campus, where I earned my Master of Engineering in Industrial Automation.
The route between those two points is the part that shaped how I design. I started as a production worker at Motion Metrics, building custom wiring and enclosures for mining equipment — hands on the hardware before I ever specified any of it. Today I'm on the other end of that: I lead FAT, SAT, and commissioning on international deployments, watching the equipment I work on run in front of the customer. You learn very quickly which design decisions survive contact with the field and which ones only ever worked in CAD.
My undergraduate capstone came from the same instinct. Two previous attempts had stalled, and what I inherited was a six-wheel chassis and nothing else. I turned it into a machine that drove.
Since then the work has kept circling one problem: machines that have to physically handle objects that refuse to be identical. A gripper light enough to swing on a harvesting arm but compliant enough not to bruise fruit. An implement that disturbs soil without damaging the crop next to it. R&D vision systems — ToF, hyperspectral, thermal, RGB — for product that arrives in a different shape every unit. You can't tolerance your way out of that kind of variation; it has to be designed into the mechanism.
When I'm not building robots, you can find me out in the mountains skiing and hiking, or exploring the world in search of delicious food — especially anything from Japan.
Technical Skills
Mechanical Design
SolidWorks • FEA • Topology Optimization • Design for 3D Printing • Mechanism & Linkage Design
Robotics
ROS • End-Effectors • Mobile Robots • Cobots & Humanoid Integration
Controls & Vision
PLC • Ignition HMI • Motion Control • Multi-Modal Machine Vision • C# / .NET • FAT, SAT & Commissioning
Selected Work
Machines that make contact.
Gripping fruit without bruising it, pulling a weed without damaging the crop beside it, grading product that arrives in a different shape every time — the same problem, at different scales.
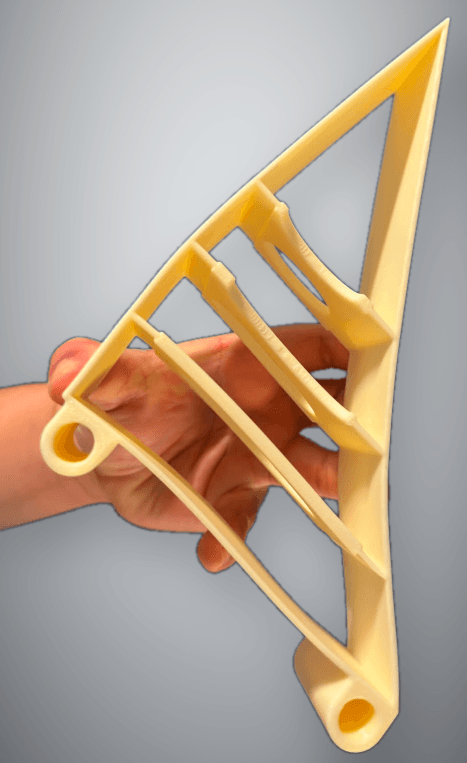
TOPOLOGY OPTIMIZATION / FEA
Soft Gripper Optimization
A compliant end-effector for fruit harvesting, taken from 130 g to 71 g through iterative FEA — then redrawn from the optimizer's raw output into geometry that could actually be printed.
View Project →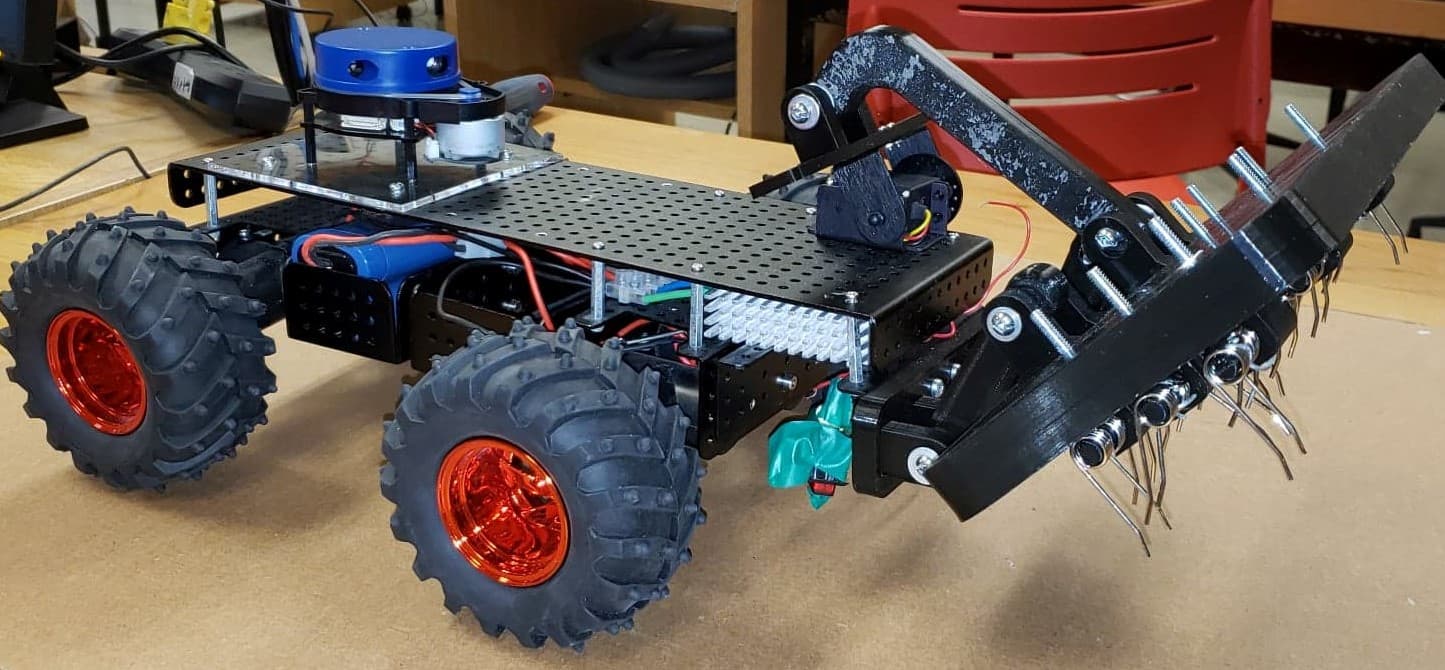
MECHANISM DESIGN / 3D PRINTING
Weed Management Robot
A robot that pulls weeds mechanically instead of spraying them. I designed the implement — a spring tine on a servo-driven four-bar lift, 15 printed parts — and modified the chassis to carry it.
View Project →Industrial Automation
Inline 3D bun inspection under 500 ms, fries grading at 120 pc/min, and commissioning on international deployments.
Explore Automation →Contact
Let's build something.
Interested in working together or learning more about my projects?